Accelerating the search for antimicrobial peptides with Google Antigravity
deepmind.google·6d ago
TL;DR
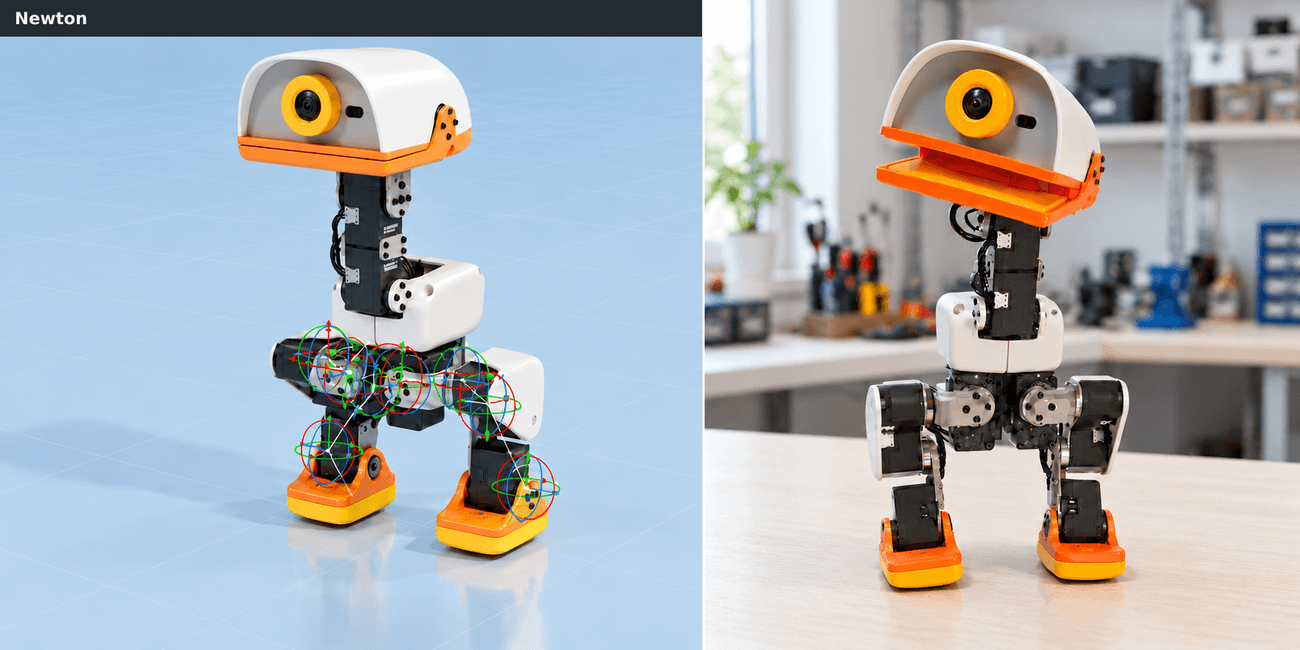
Microduck, an affordable open-source bipedal robot, can now be trained to walk using NVIDIA's Isaac Lab and Newton. Users can export walking policies as ONNX and deploy them on the real robot, facilitating advanced robotics tasks.
✦ Why It Matters
Start training your own walking policies for Microduck today using Isaac Lab and Newton.
Key Takeaways
How It Works
The training process leverages NVIDIA Isaac Lab's GPU-parallel simulations to create realistic environments for Microduck. By employing domain randomization, developers can vary parameters like mass and friction during training, ensuring the robot learns to adapt to real-world conditions.
This approach helps in modeling mechanical delays and backlash, which are critical for effective policy transfer from simulation to hardware.
Related